Completion of Undergraduate Graduation Project
Published:
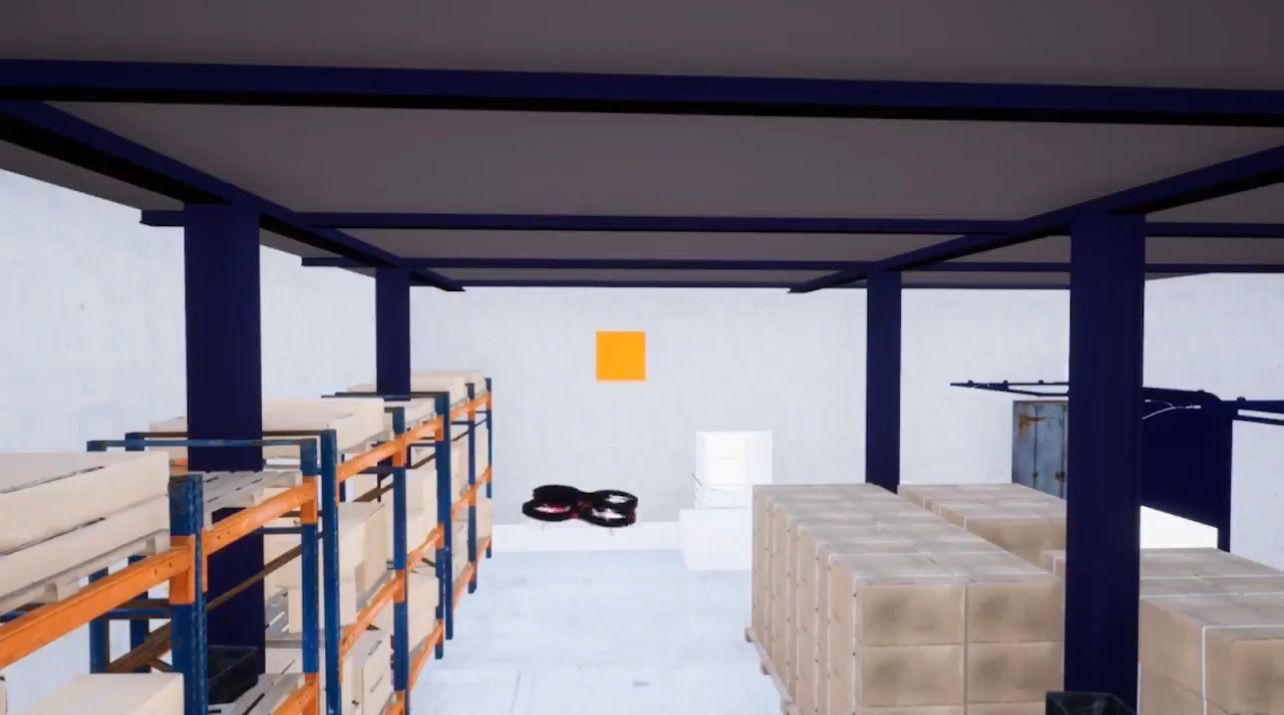
Successfully Completed our research-based project, “Autonomous UAV Path Planning in AirSim Using Reinforcement Learning,” with a grade of A (4.0/4.0) at the University of Jordan. Our research explored autonomous UAV path planning using a Proximal Policy Optimization (PPO)-based single-agent system and a preliminary Multi-Agent Deep Deterministic Policy Gradient (MADDPG) framework for decentralized multi-UAV coordination. Both systems were trained in AirSim’s physics-rich warehouse environment.